Seven cameras, one Gigabit uplink.
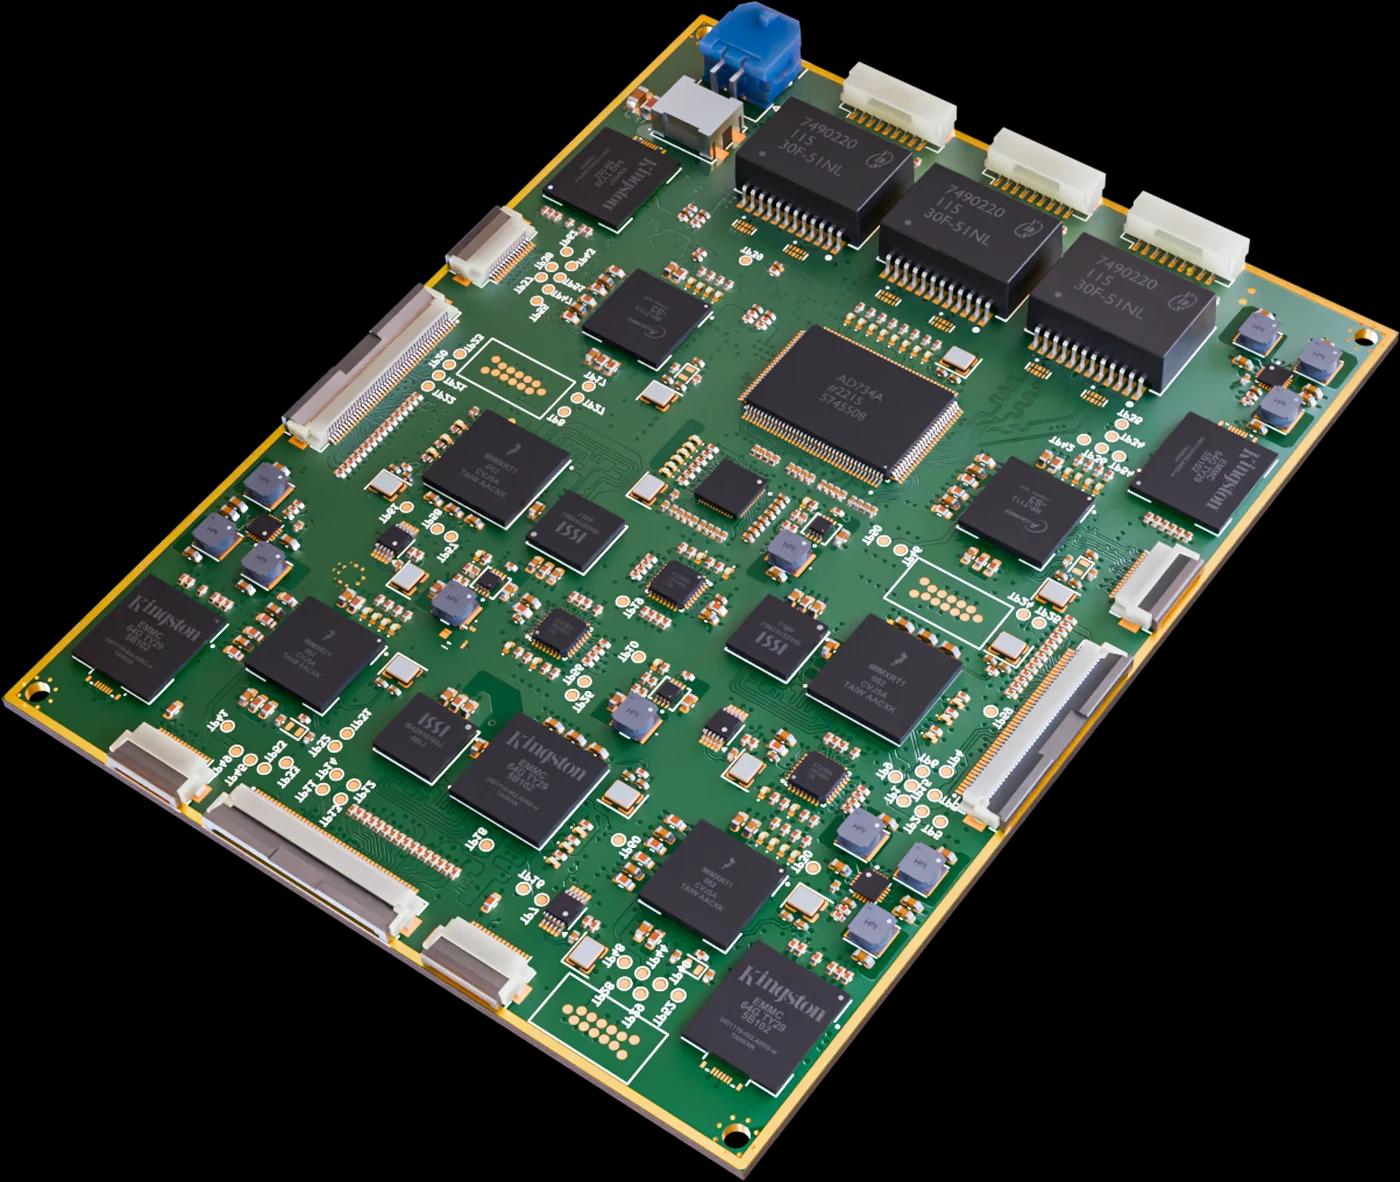
Robotics perception main board that brings 3 Time-of-Flight cameras and 4 standard 2D cameras onto one Gigabit Ethernet uplink. Each camera has its own processor and memory, and two daisy-chained Ethernet switches combine all streams on a controlled-impedance multilayer board.
The board
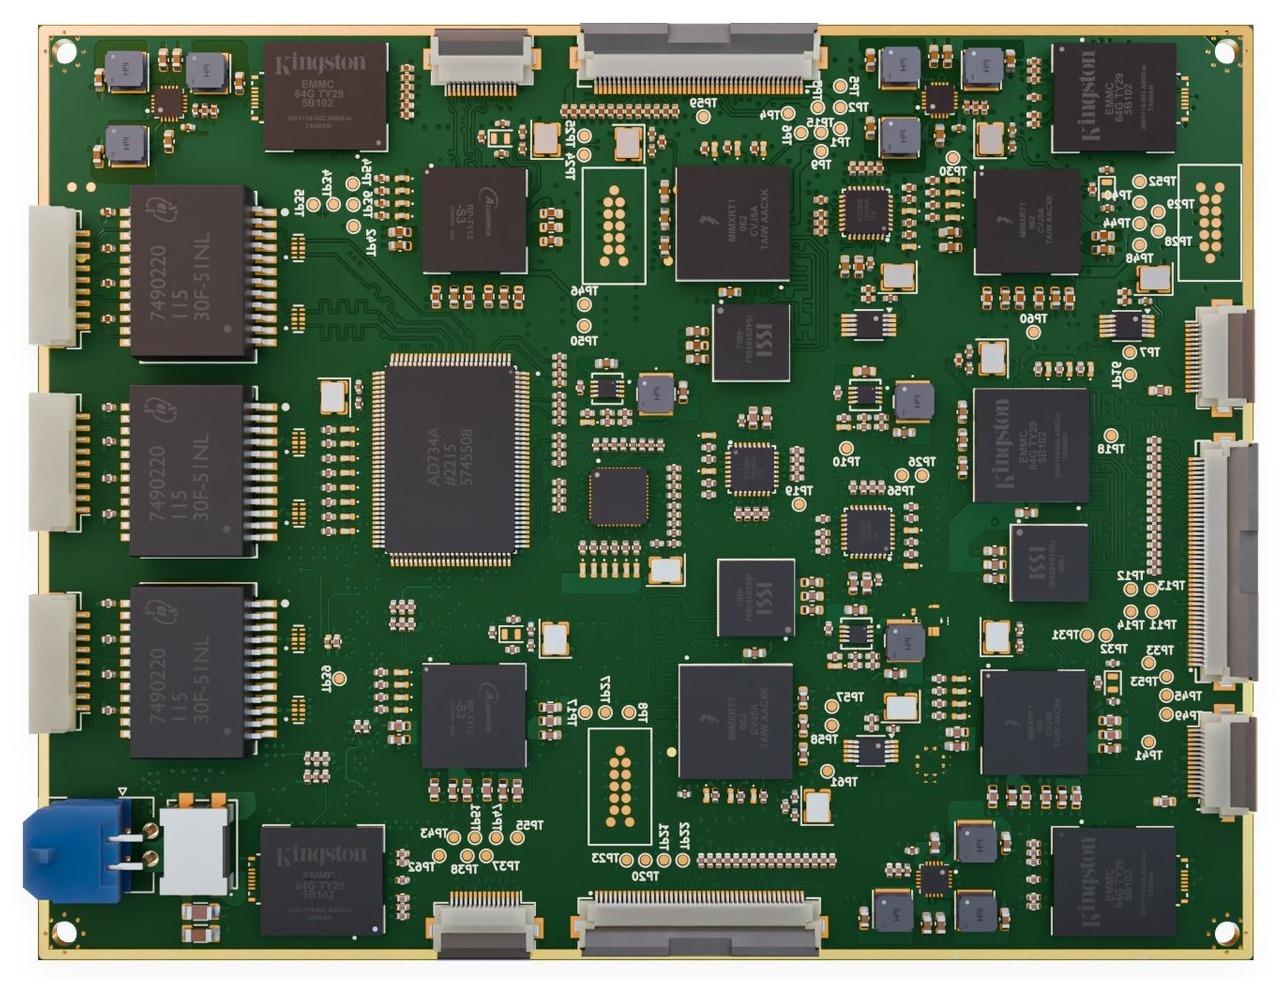
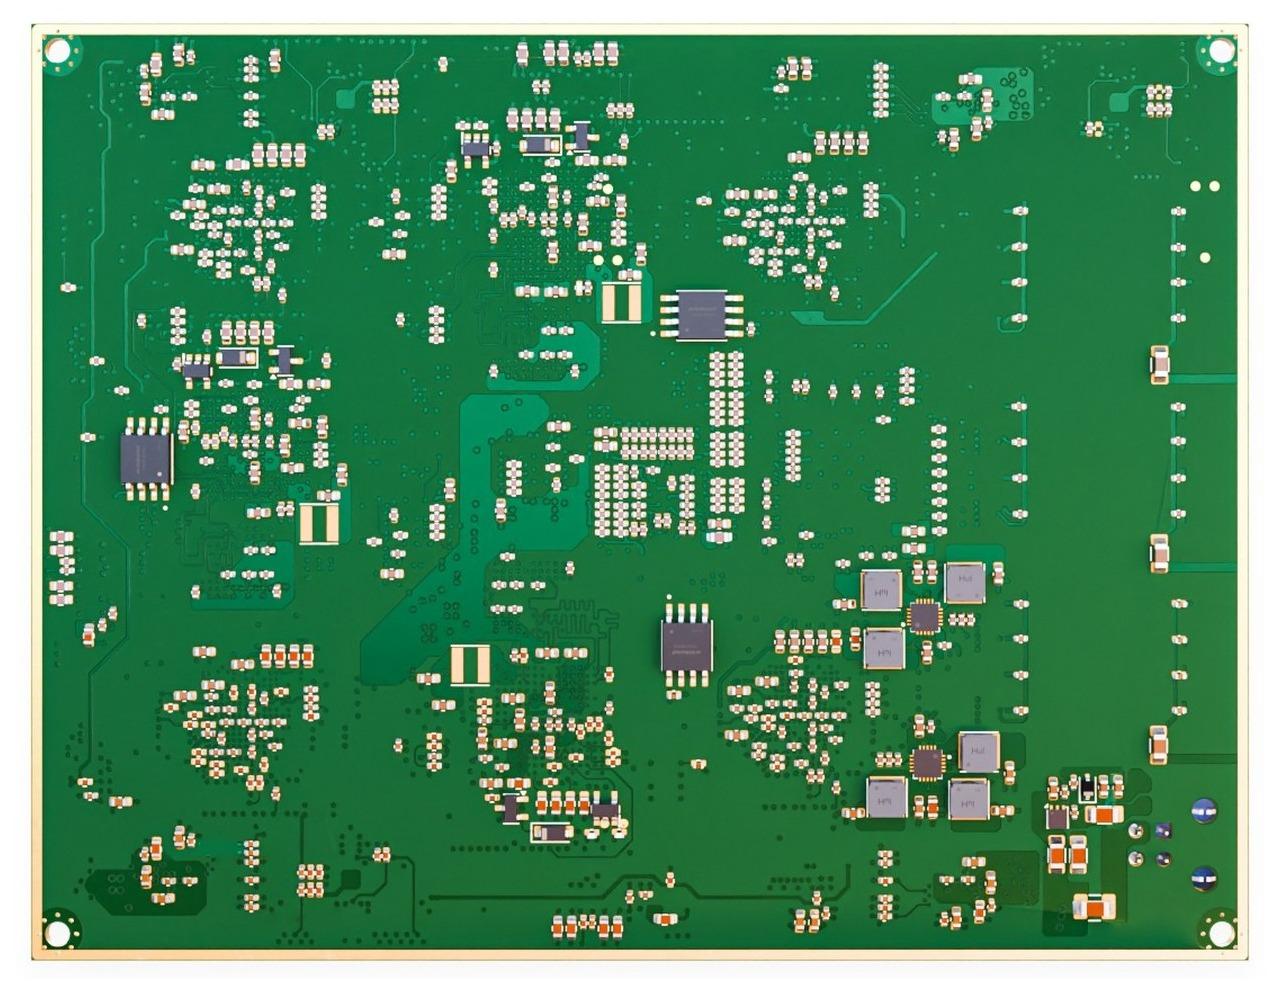
The board measures 5118 × 3937 mil and is built on 8 layers (5 signal and 3 plane) with a finished thickness of 64.4 mil. It carries 1,302 components and was designed in KiCad, with controlled-impedance routing for its Gigabit and Fast Ethernet links.
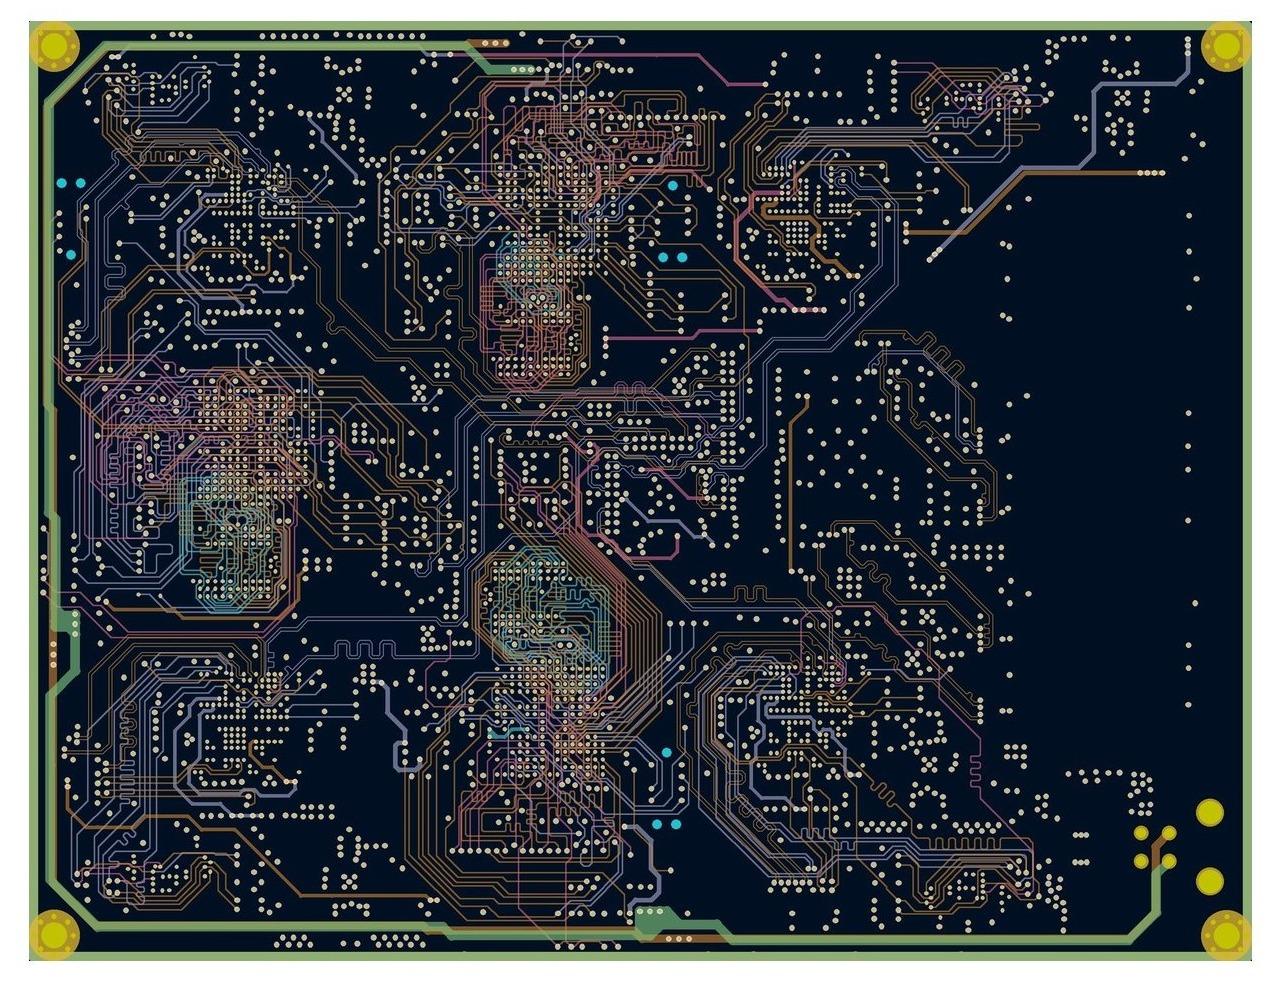
All signal and plane layers of the 8-layer stack-up combined: controlled-impedance Ethernet links, dense BGA fan-out with via-in-pad, and 3.9 mil / 3.9 mil design rules.
Design highlights
Daisy-chained RTL8370N Gigabit and IP175G Fast-Ethernet switches carry 7 camera streams to a single uplink.
Transformerless, AC-coupled Ethernet links between the switches and the on-board camera MPU PHYs.
Four Allwinner S3 BGA camera processors and three i.MX RT1062 BGA ToF processors on one board.
Local power generation per module from the common +5 V input; isolated LED supply routed through.
0201 / 0402 passives, via-in-pad and 3.9 mil / 3.9 mil design rules for dense BGA fan-out.
Building something similar?
Multi-camera, edge AI or high-speed boards. Talk to the team that designed this one.
