A carrier board for NVIDIA's flagship robotics computer.
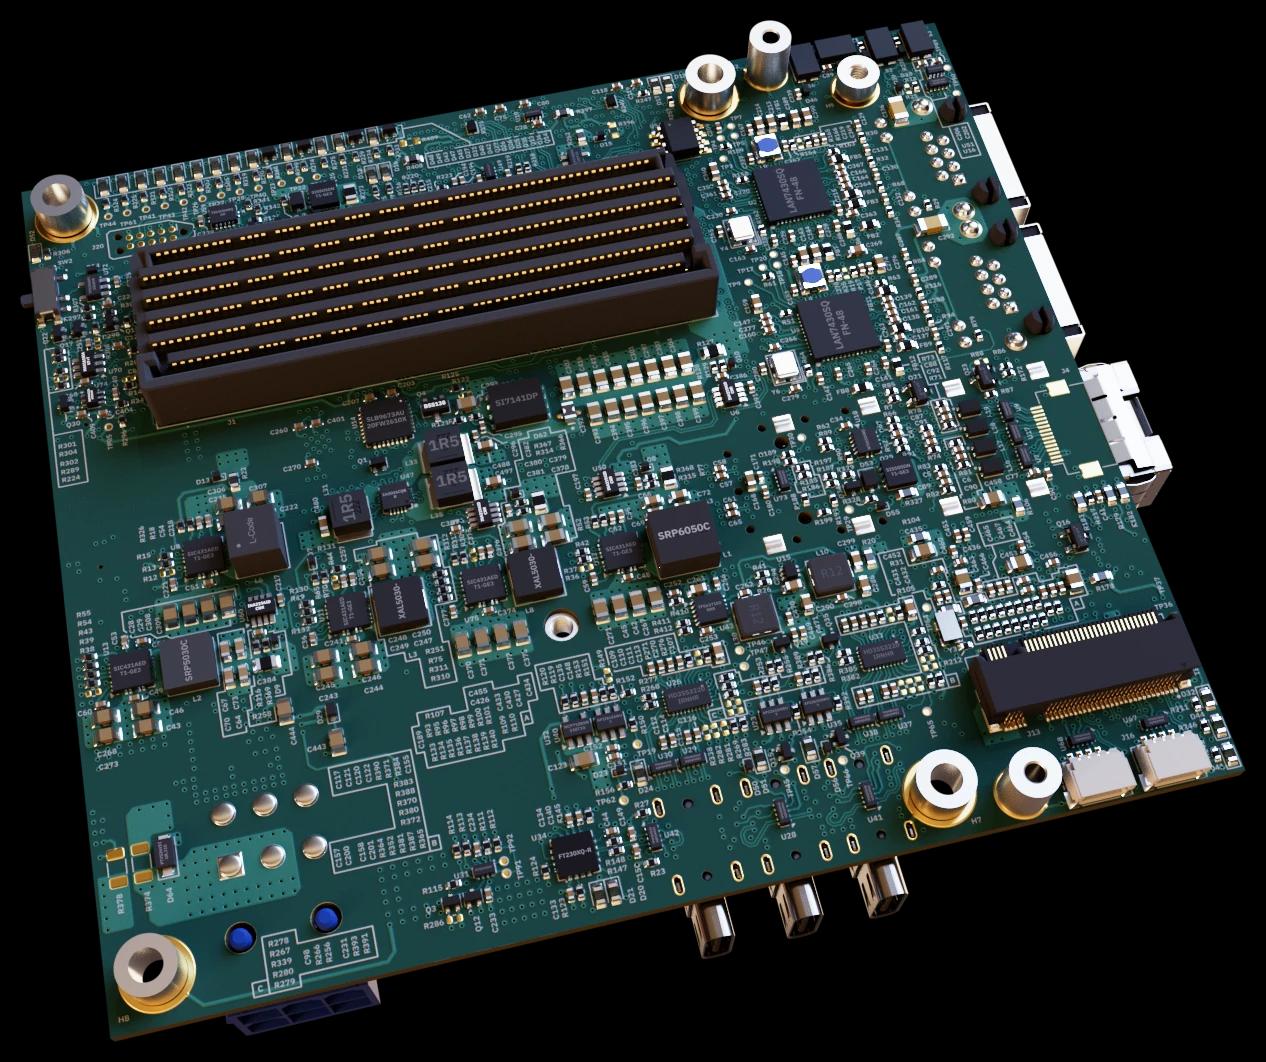
Carrier board for the NVIDIA Jetson Thor module, built for robotics. It brings out multi-gigabit and Gigabit Ethernet, HDMI, USB-C, M.2 expansion, camera and coaxial I/O, audio and a TPM around the module's high-density board-to-board connector, with its own wide-input power stage. Designed in KiCad on a 12-layer stack-up.
The board
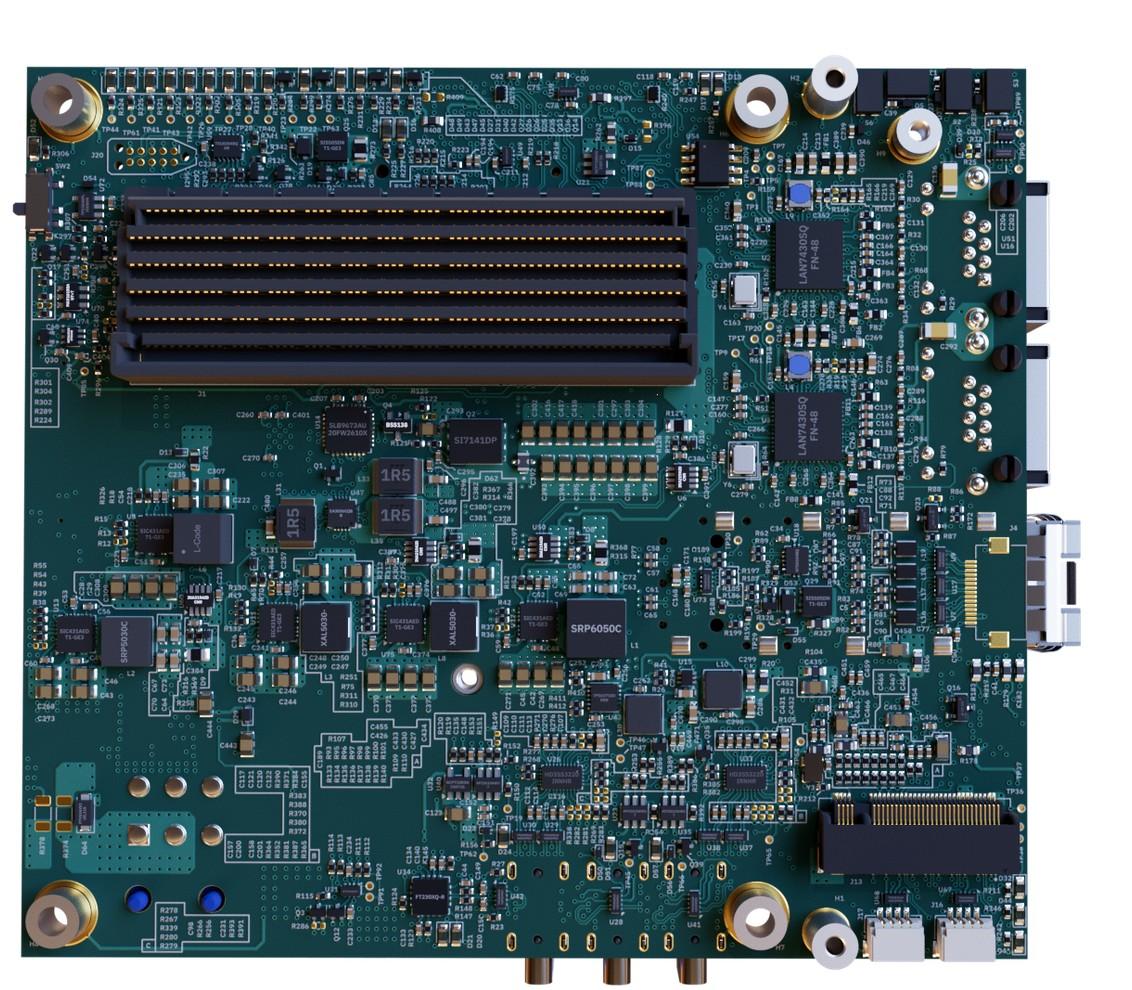
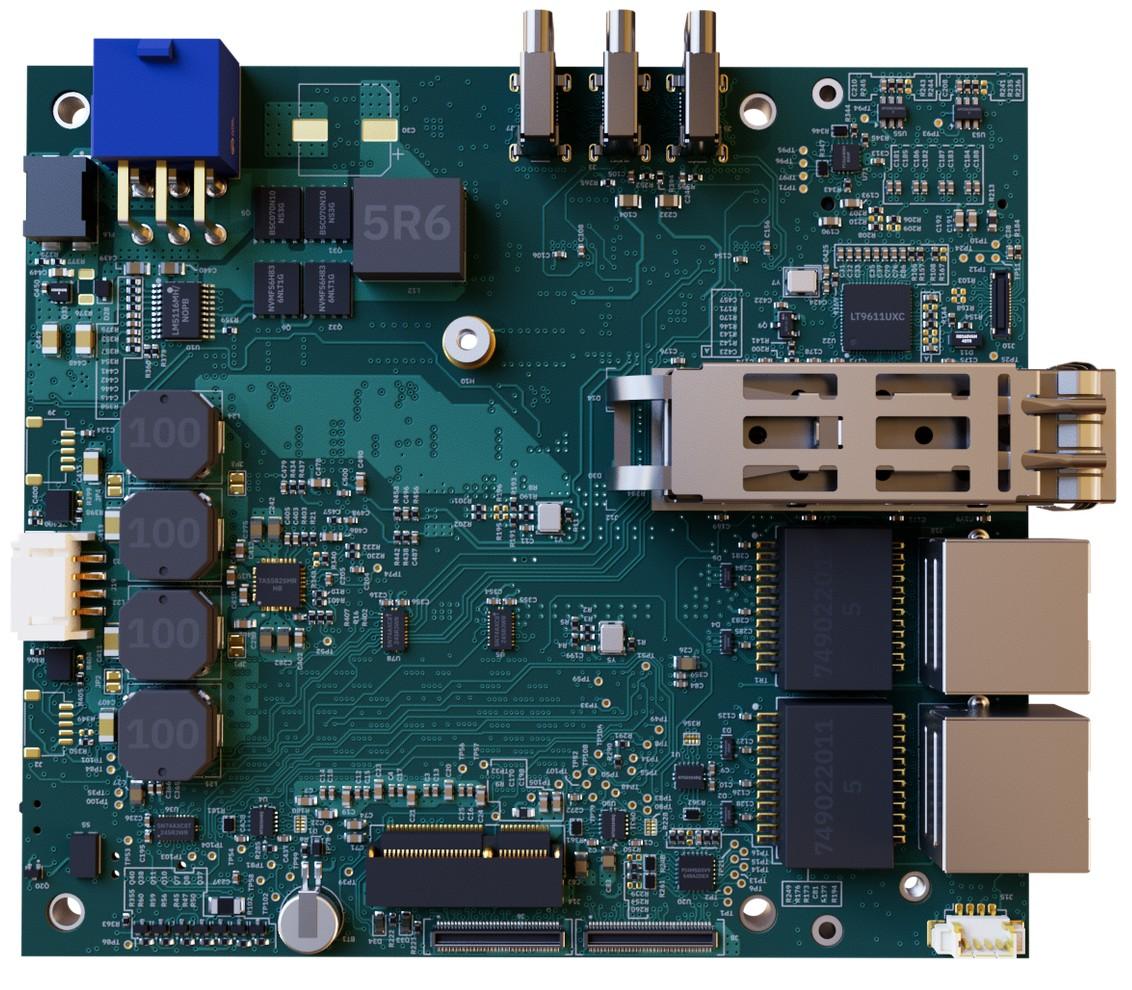
The 12-layer board is built around the Jetson Thor's high-density board-to-board connector. It adds an optical transceiver cage, two RJ45 ports with magnetics, two Microchip LAN7430 Gigabit Ethernet controllers, a Lontium LT9611UXC HDMI bridge, USB-C ports managed by TI HD3SS3220 controllers, two M.2 sockets, three coaxial connectors and two flat-flex camera/display connectors. Power comes from a wide-input TI LM5116 buck stage with Infineon MOSFETs, followed by Vishay SiC431 point-of-load converters.
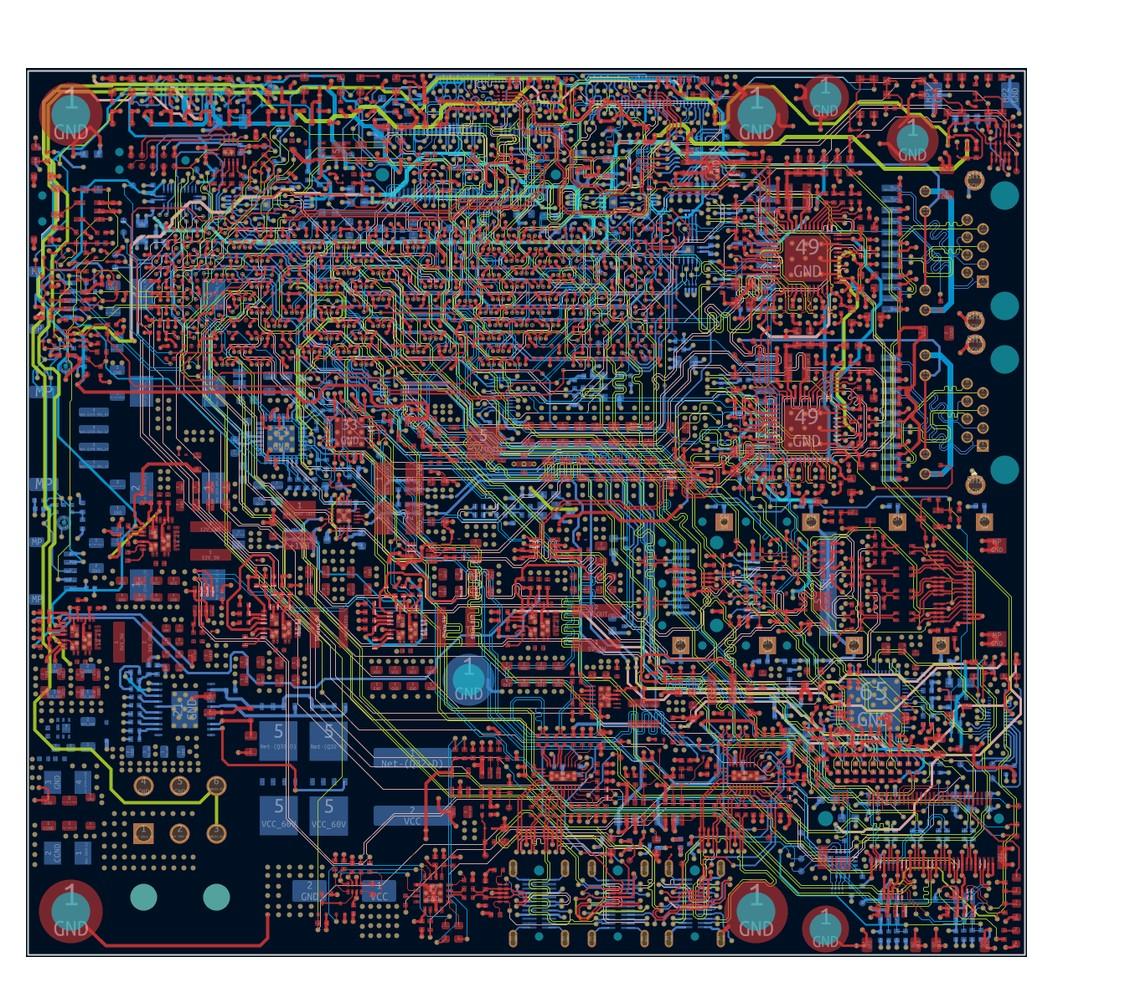
All layers combined: the module connector fans out across the top of the board into high-speed Ethernet, HDMI, USB and PCIe routing, while the power stages are grouped on the left with wide copper pours kept clear of the signal area.
Design highlights
High-density board-to-board connector for the Jetson Thor module, with its signals fanned out to every edge of the board.
Optical transceiver cage and two RJ45 ports with magnetics, plus two Microchip LAN7430 Gigabit Ethernet controllers.
Lontium LT9611UXC HDMI bridge and USB-C ports managed by TI HD3SS3220 controllers.
Two M.2 sockets, three coaxial connectors and two flat-flex connectors for cameras and displays.
Wide-input TI LM5116 buck stage with Infineon power MOSFETs, then Vishay SiC431 point-of-load converters for the board rails.
Infineon SLB9673 TPM, TI TAS5825M audio amplifier and an FTDI USB-UART for debug.
Building something similar?
Multi-camera, edge AI or high-speed boards. Talk to the team that designed this one.
